Your robot breaks down. Know before it does.

See which robot needs help, why, and how to fix it, before a small issue turns into costly downtime.

TELEMETRY LOGS CONFIG FAULT CODES CAN BUS Faros ON THE ROBOT TELEMETRY LOGS CONFIG FAULT CODES CAN BUS Faros ON THE ROBOT
Found a problem AMR
Root cause

The load is off to one side

The robot is fighting the steering the whole way

Normal

It’s working 15% harder to drive straight than it was last week
Every minute of lost production has a measurable cost.

Downtime

Robot Failure

A robot goes down mid-task and its output goes to zero. Everything that depended on it slows, and the day's productivity goes with it.

Throughput

One Stuck Robot Blocks More Than Itself

A robot down in the field isn't an isolated problem. Tasks get reassigned, routes back up, and someone has to drive out and deal with it.

Maintenance

Found Too Late

By the time a reading finally crosses a limit, the small fault has become a replacement, and a scheduled stop has become an unplanned one.

Warning

It Works Right Up Until It Doesn't

Robots compensate for their own faults. Performance looks fine, tasks keep completing, and nothing in your fleet software changes until the robot fails.

Introducing

Faros

An edge-native fault detection system that runs on the robot itself.

Faros watches how sensor readings move together then says what changed and how to fix it before the robot fails.

1

Listen

Faros taps into the robot's own signals: motors, sensors and telemetry. It reads them right on the hardware, in real time.

Learn

It builds a model of what normal looks like for each individual robot.

Catch

When behaviour drifts from normal, Faros flags it early, before it becomes a breakdown in the field.

Explain

Every alert comes with the why and the what to do. Your team fixes it fast and efficiently.

Where it fits

Built for the robots you already run, indoors and outdoors.

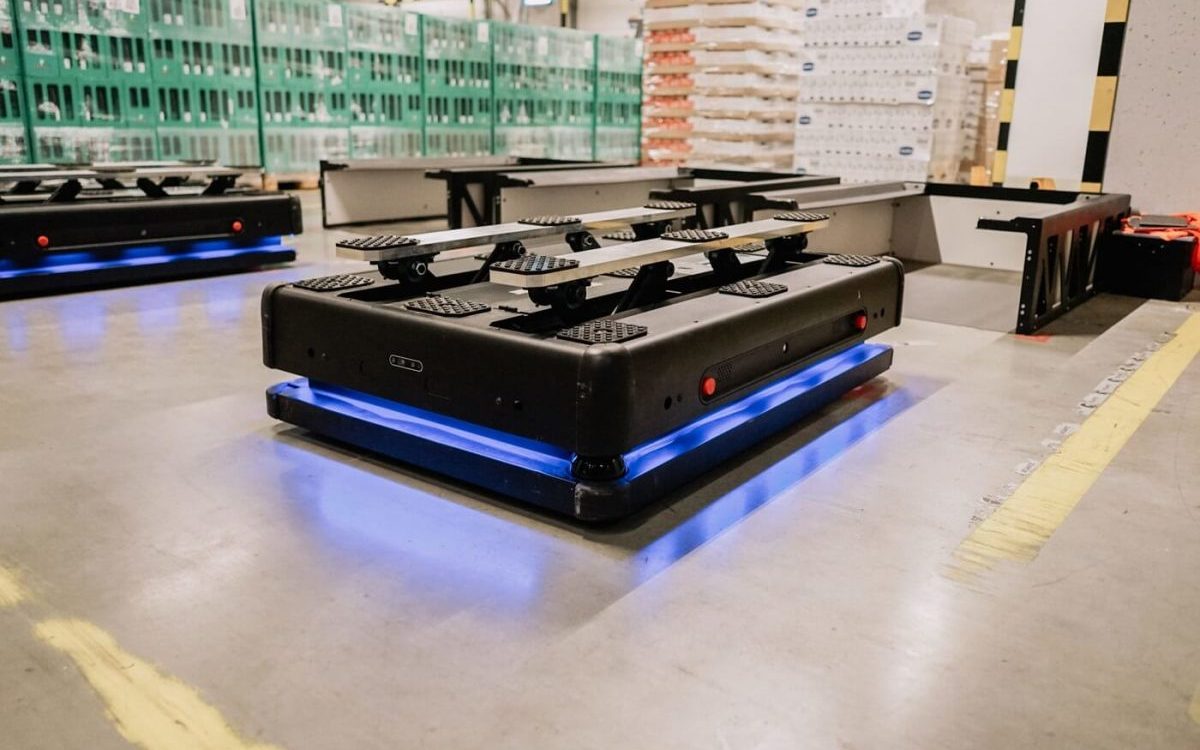
Warehouse robots carrying stock between racking

Runs on the robot, not the cloud

No streaming data offsite, no cloud dependency. It works where the robot works.

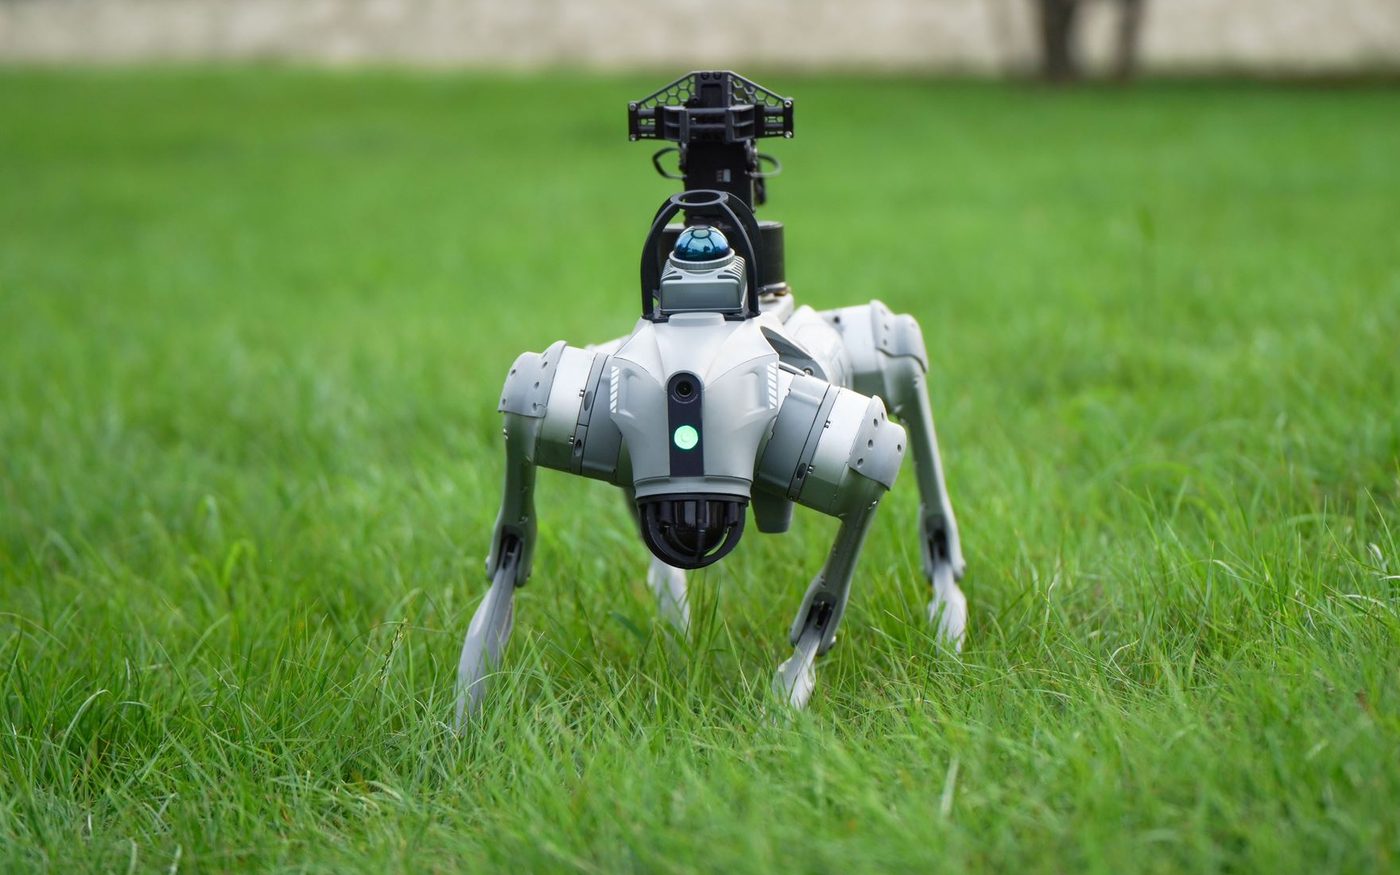
A four-legged robot carrying a lidar unit, walking through grass

Learns from healthy runs

Record the robot working normally and that becomes its baseline.

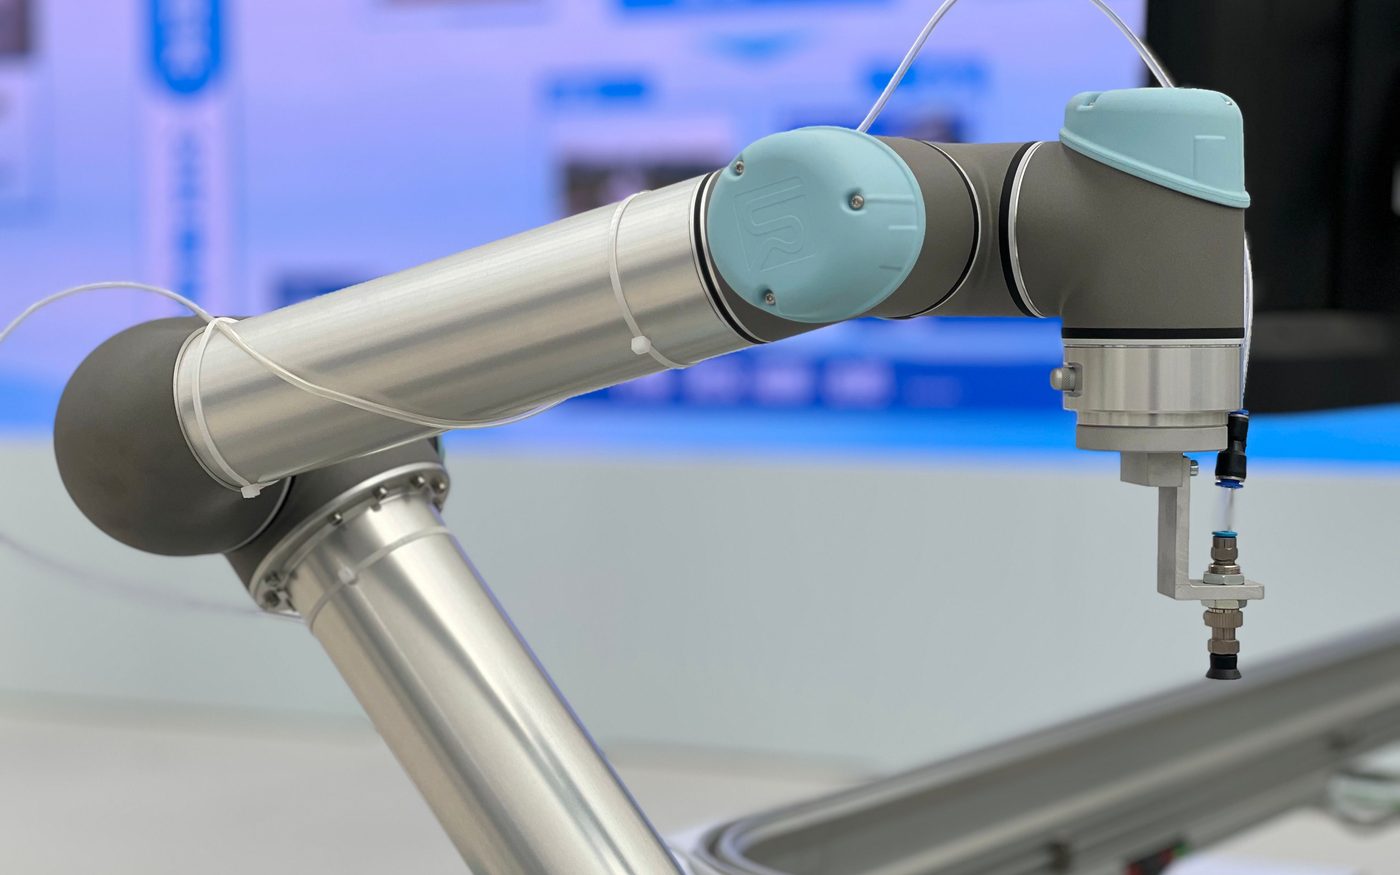
Close view of a collaborative robot arm and its gripper

Uses your existing sensors

It reads what the robot already publishes. No extra instrumentation, no retrofit.

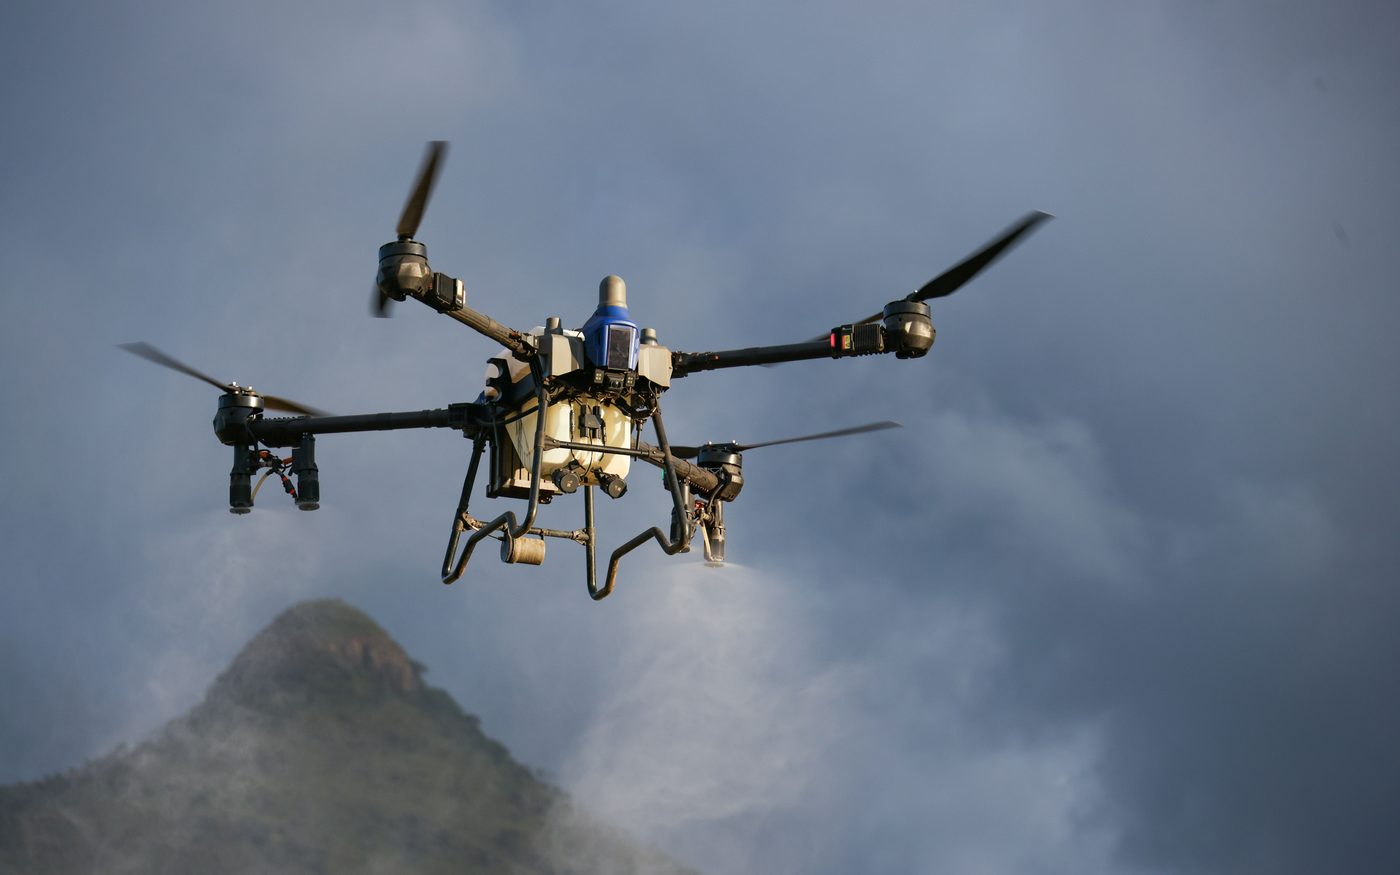
A spraying drone in flight over open country

Lightweight by design

Minimal CPU, minimal memory, no strain on bandwidth. Your robot's real workload always comes first.

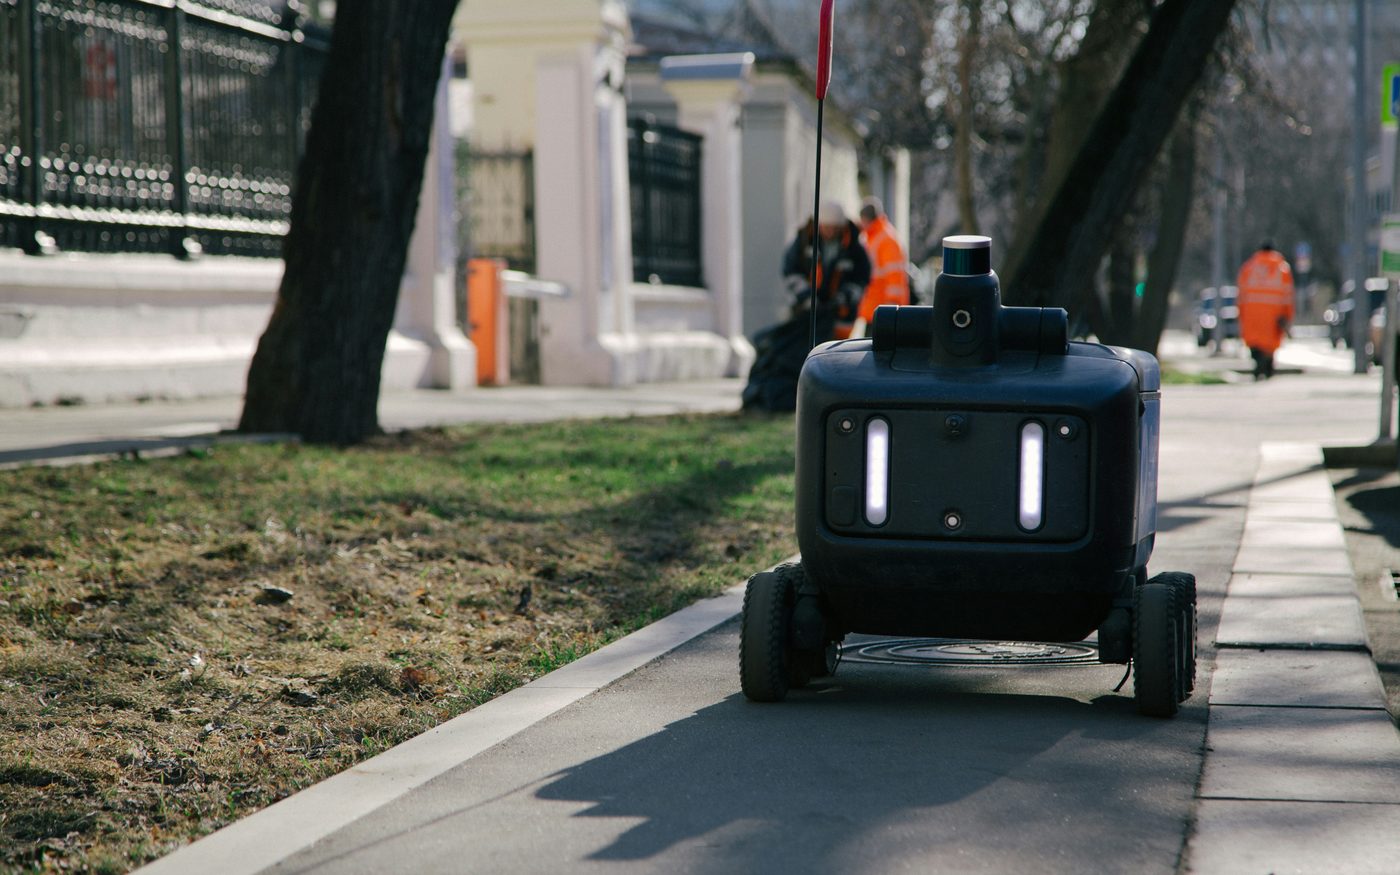
A delivery robot travelling along a city pavement

Works with any robot

It watches how the readings move together. Any brand, any model.

Measured

Faros runs on low compute,
right on the robot.

We tested Faros on a Raspberry Pi 4, which is about as small a computer as you would ever run it on. It barely used any of the board. If it runs comfortably there, it will run on whatever your robot already has. No extra hardware, no GPU.

Resource Faros uses Out of Total used in %
Processor 12% of one coreof 4 cores 4 cores 3%
Memory 203 MBof 4 GB 4 GB 5%
Time, each second 34 ms62 ms at worstof 1,000 ms 1,000 ms 3%

Tested on a Raspberry Pi 4, 4× Cortex-A72 @ 1.5 GHz, 4 GB RAM

Watch

See it catch something

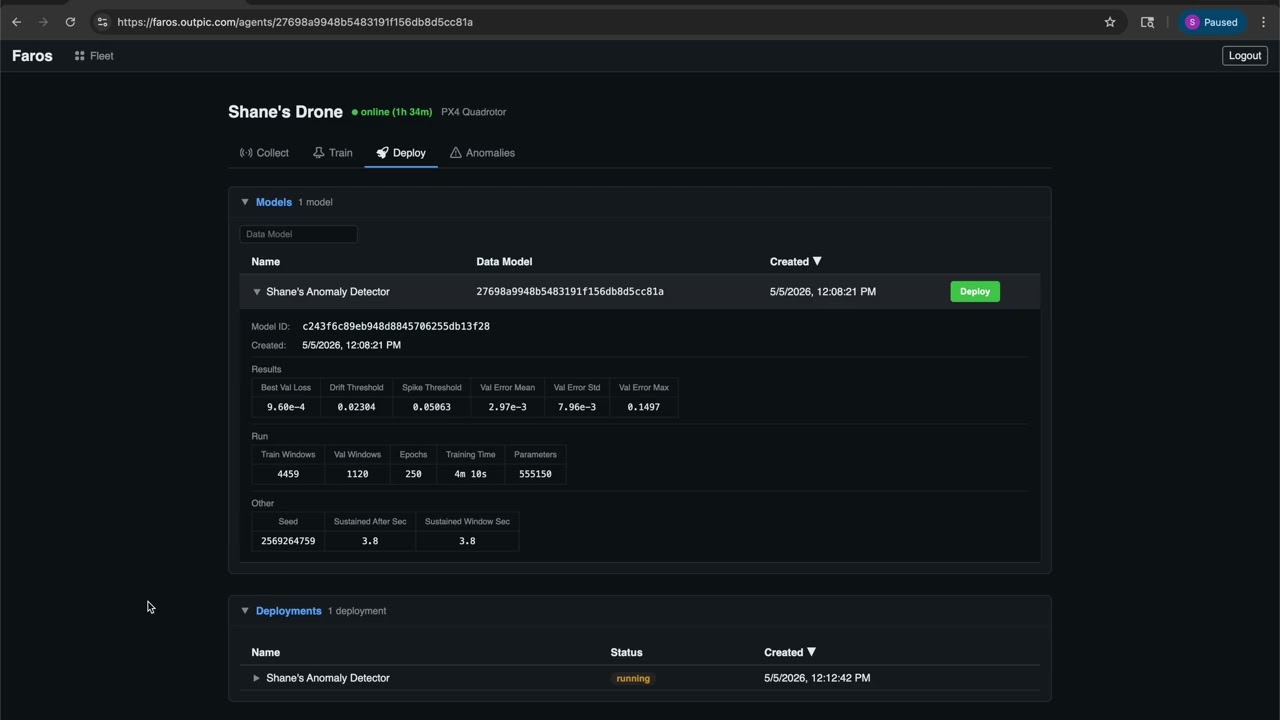
The demo uses a drone because a failing motor is easy to picture. Nothing about the way it works is specific to drones.

Live demo
Get started

Book a Demo.

Catch faults before they stop the robot in production.